UCLA VAIL Lab
Autonomous navigation2×

ChairNav

Cross-Embodiment Pretraining and Personalization for Long-Horizon Wheelchair Navigation

1 University of California, Los Angeles 2 Louisiana State University * Equal contribution

The platform

A wheelchair built for learning.

Wheelchair platform

Data / control×Original link interrupted

The approach

From general driving to rider preferences.
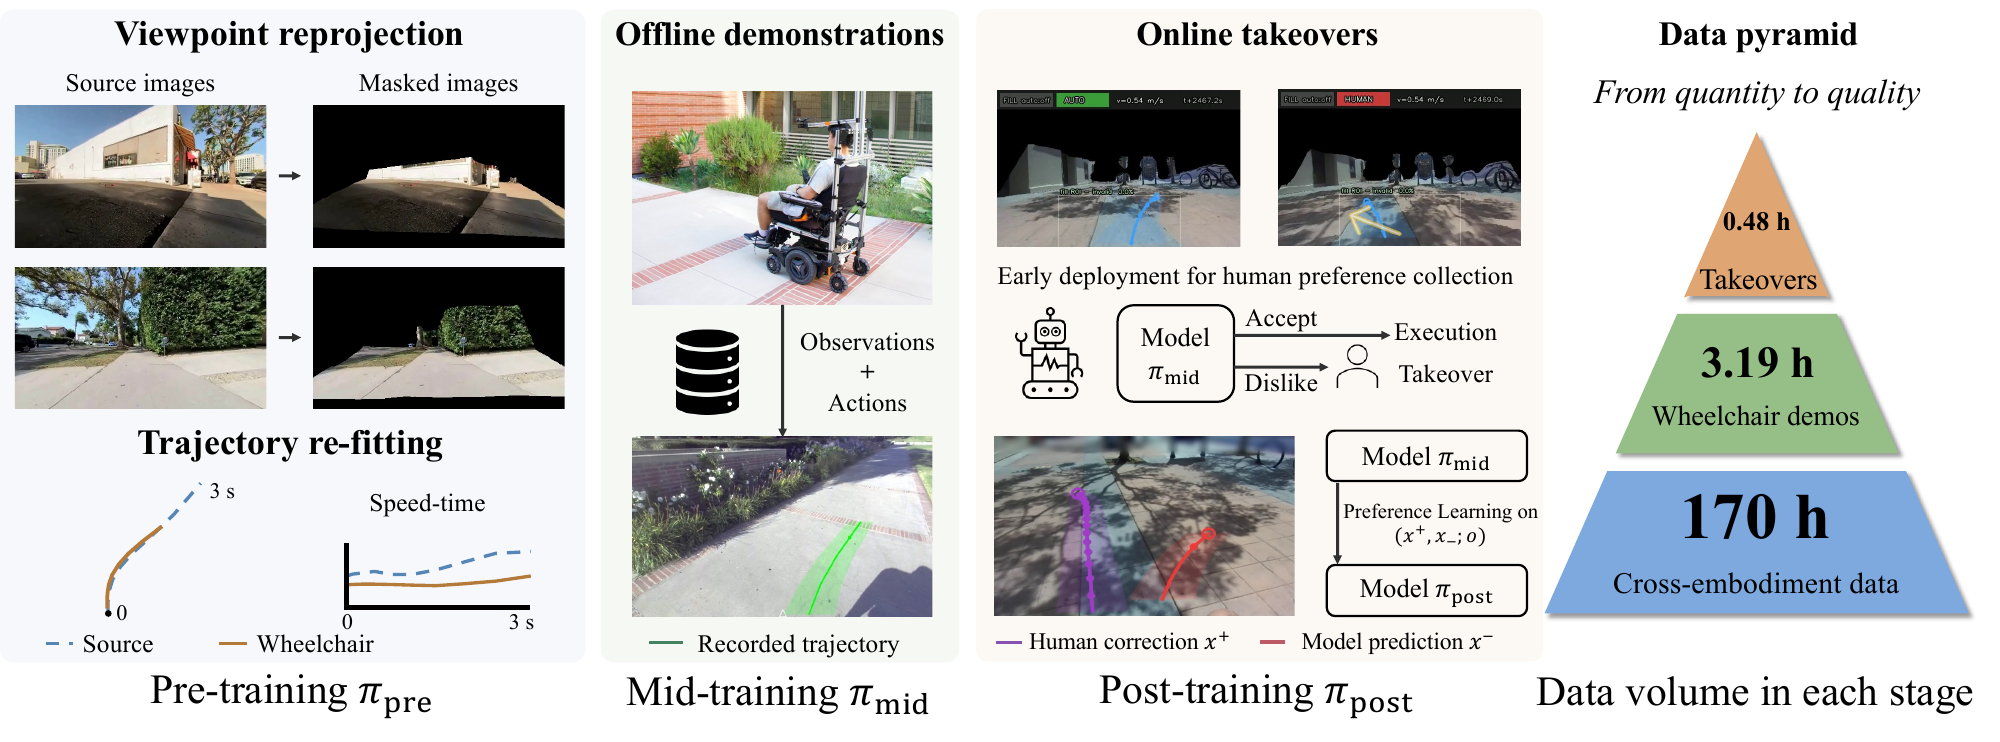
ChairNav overview: adapt delivery robot observations and trajectories, learn from human wheelchair demonstrations, then learn from rider interventions.
Choose a stage to explore.Full figure ↗

In the real world

Long-horizon navigation.

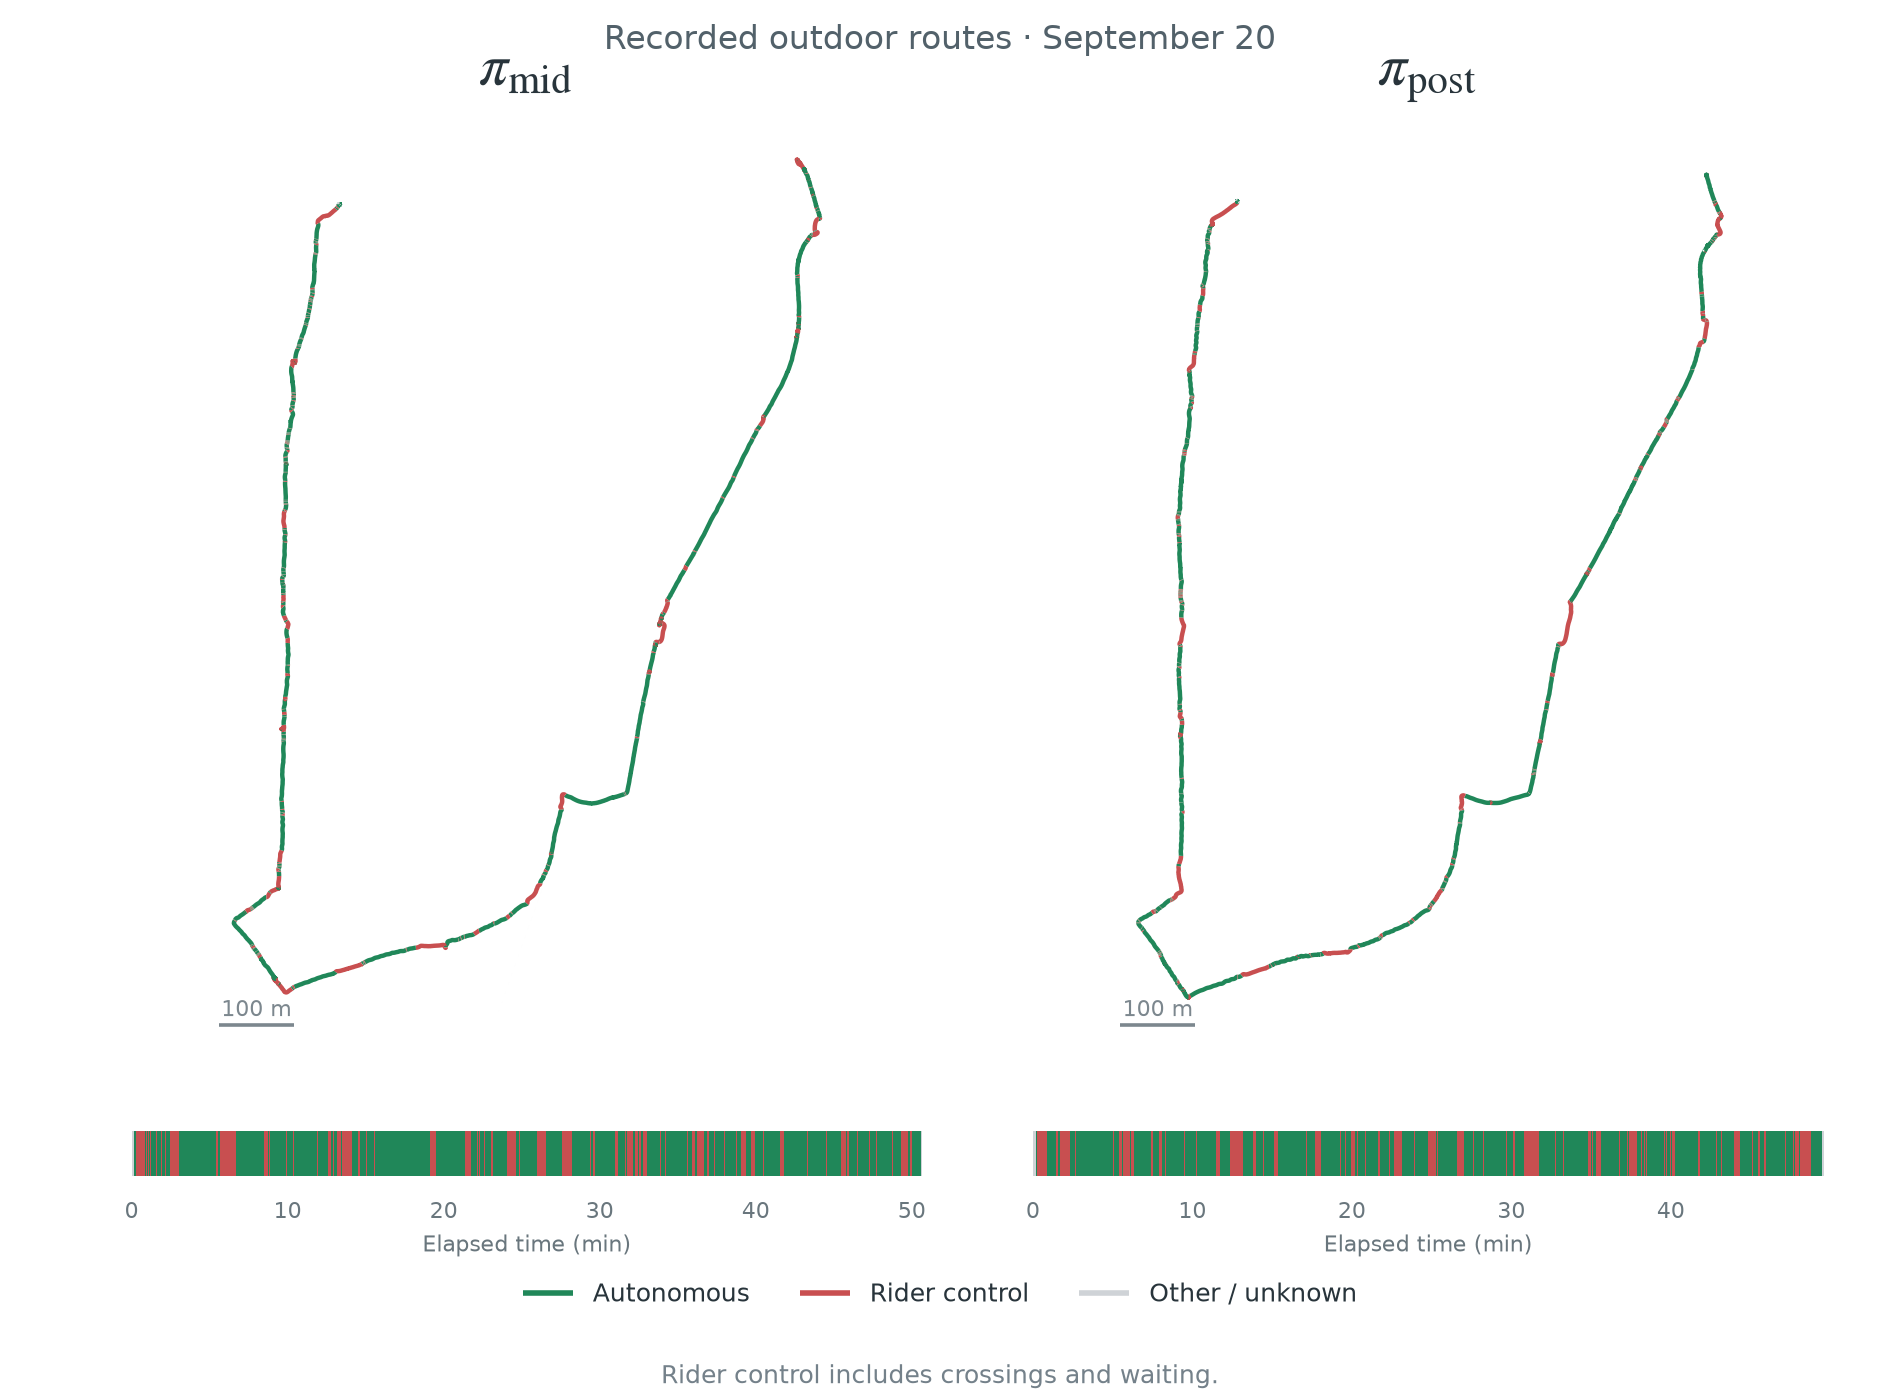
Full-route control-state maps
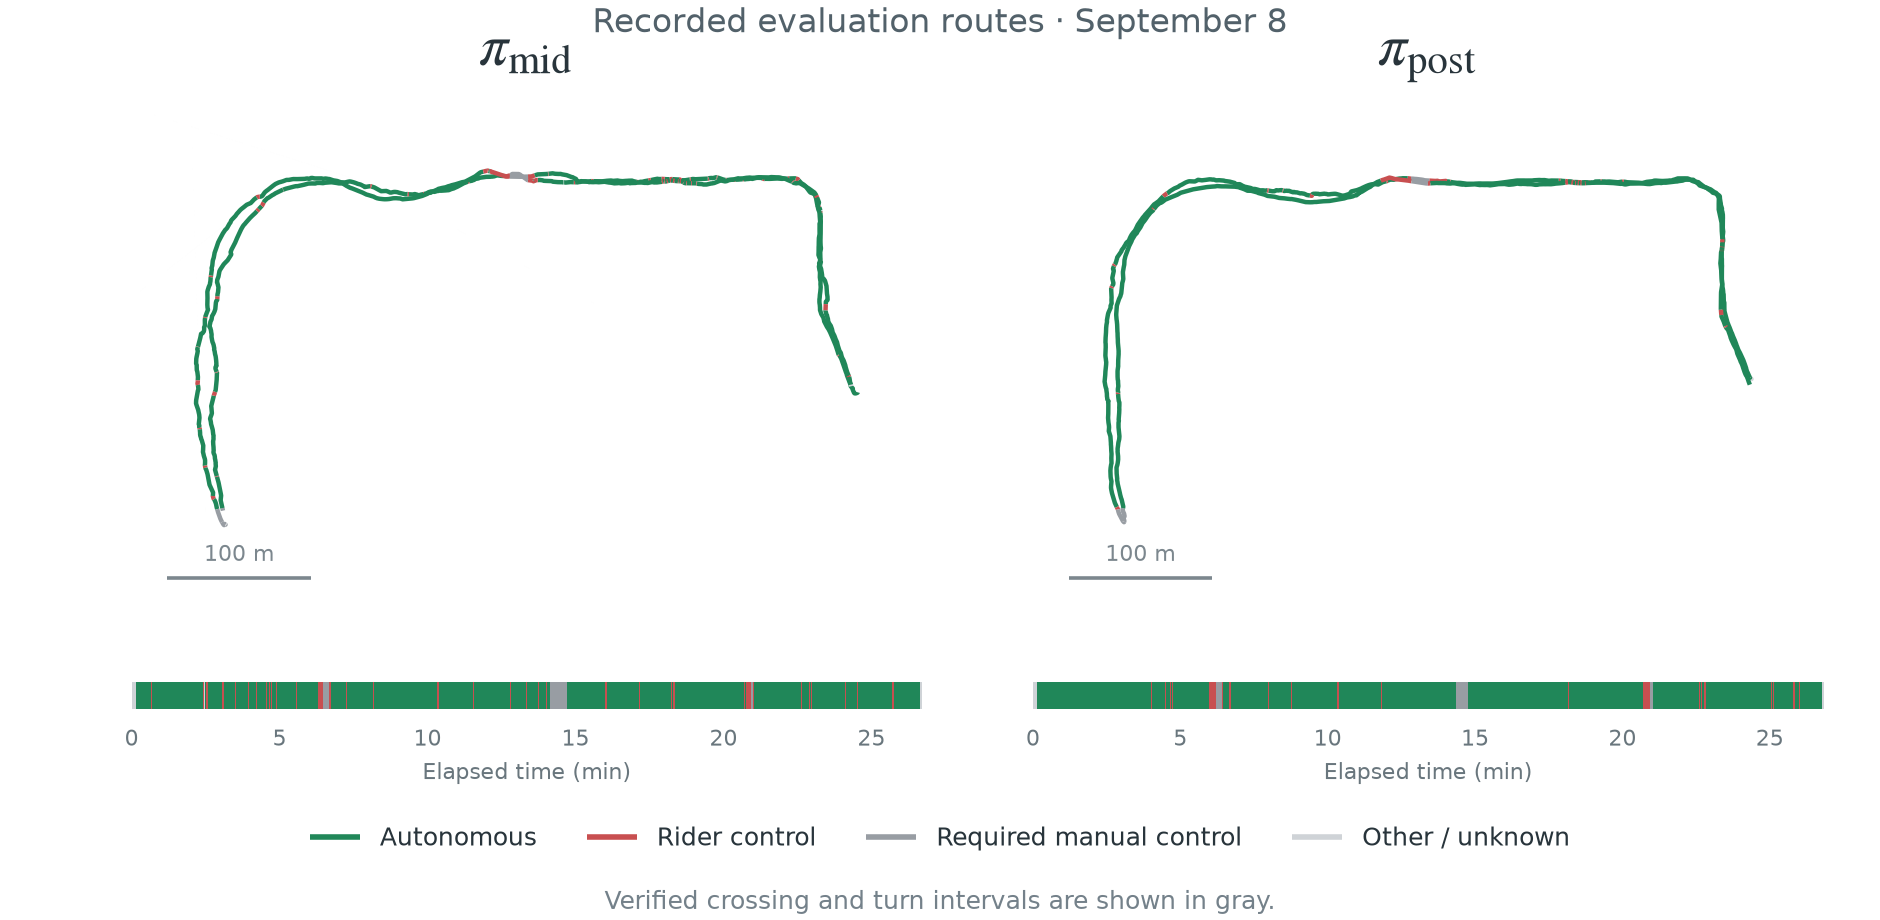
MID and POST recorded routes and control states
September 8 · evaluation route
MID and POST recorded routes and control states
September 20 · outdoor route

One recorded run per policy. Rider control includes crossings and waiting.

Citation

BibTeX will be added when the arXiv preprint is available.

arXiv citation coming soon

Qualitative results

The same places, across policies.

Matched locations from separate drives.

Passing a gatepost.

MID: rider correction. POST: autonomous passage.

πmidRecorded run
πpostRecorded run
−6.0 s
Comparison details

Matched by route position, not time. Approach, lighting, and bin placement differ between the two drives.

1× playback. Zero marks the MID intervention and the matched POST location.

Three policies evaluated on one shared observation at this scene

Offline predictions on one shared observation.

Following a hedge.

Both drives include rider corrections.

πmidRecorded run
πpostRecorded run
−6.0 s
Comparison details

Matched by route position. MID and POST predictions on the same input differ only slightly through most of this window.

1× playback. Zero marks the MID intervention and the matched POST location.

Three policies evaluated on one shared observation at this scene

Offline predictions on one shared observation.

Challenging cases

Where rider assistance is still needed.

Rider interventionπpost

Beside a sidewalk column.

POST needs a correction; MID passes this location.

See the MID recording at this location
πmidPrediction + rider input
Close approachπpost

Beside a bicycle dock.

Rider-reported collision; impact time unverified.

See the MID recording at this location
πmidPrediction + rider input